Embedded systems & controls
Sensor and actuator integration, control logic, hardware/software interfaces, C/C++, C#, Python, electrical design, and practical bring-up.
MAKE THE HARDWARE BEHAVE ↗Good. Neither should the solution.
My depth is in high-voltage EV systems and hardware controls. My advantage is what happens beyond them: mechanical design, embedded software, robotics, fabrication, manufacturing, and field troubleshooting. I connect the disciplines and take ownership of making the whole system work.
The hardest failures happen at the interfaces. I bring real depth in electrical power and hardware controls, plus the mechanical, software, manufacturing, and field fluency to make sound tradeoffs, connect specialists, and move the entire system forward.
Sensor and actuator integration, control logic, hardware/software interfaces, C/C++, C#, Python, electrical design, and practical bring-up.
MAKE THE HARDWARE BEHAVE ↗Inventor and SolidWorks, manufacturing tradeoffs, CNC milling, laser cutting, extensive 3D printing, electronics assembly, and close machine-shop collaboration.
FROM CAD TO REAL PARTS ↗Autonomous vehicle development, competition robotics, electromechanical machinery, sensing, motion, test rigs, and system integration.
BUILD AND OPERATE ↗Signal tracing, thermal modeling, pneumatic and electrical root-cause investigations, controlled testing, troubleshooting, and equipment commissioning support.
FOLLOW THE EVIDENCE ↗Ambiguous requirements, prototype budgets, vendor coordination, manufacturing partners, technical communication, and startup development through MassChallenge.
MOVE WITHOUT PERFECT INPUTS ↗HyperMotionWorks is new. The engineering experience behind it isn't. These examples come from previous roles, teams, and independent builds, not HyperMotionWorks client engagements.
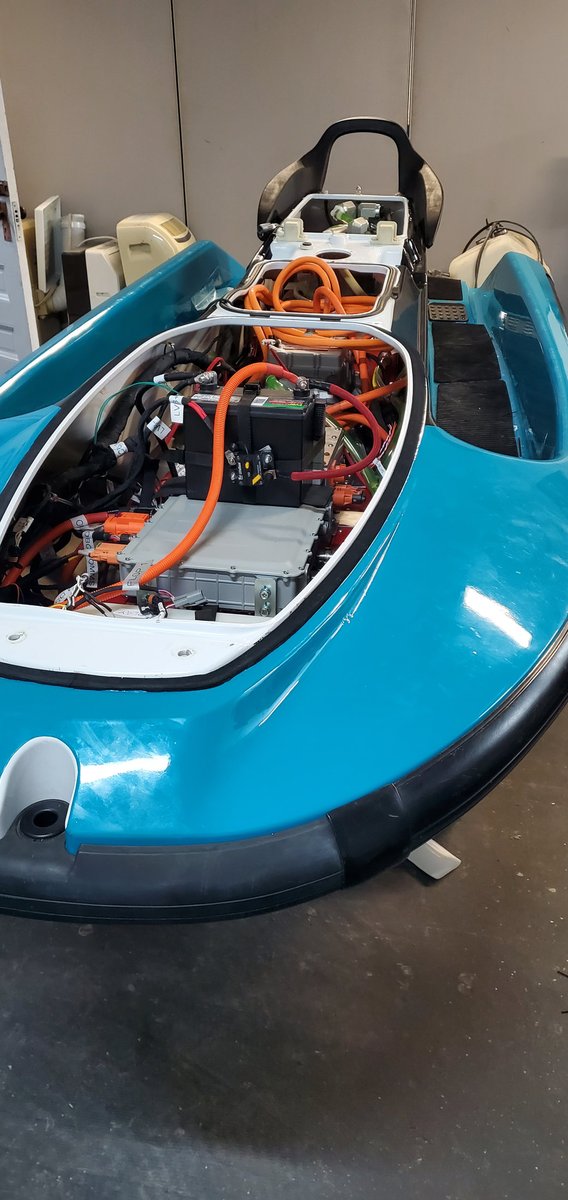
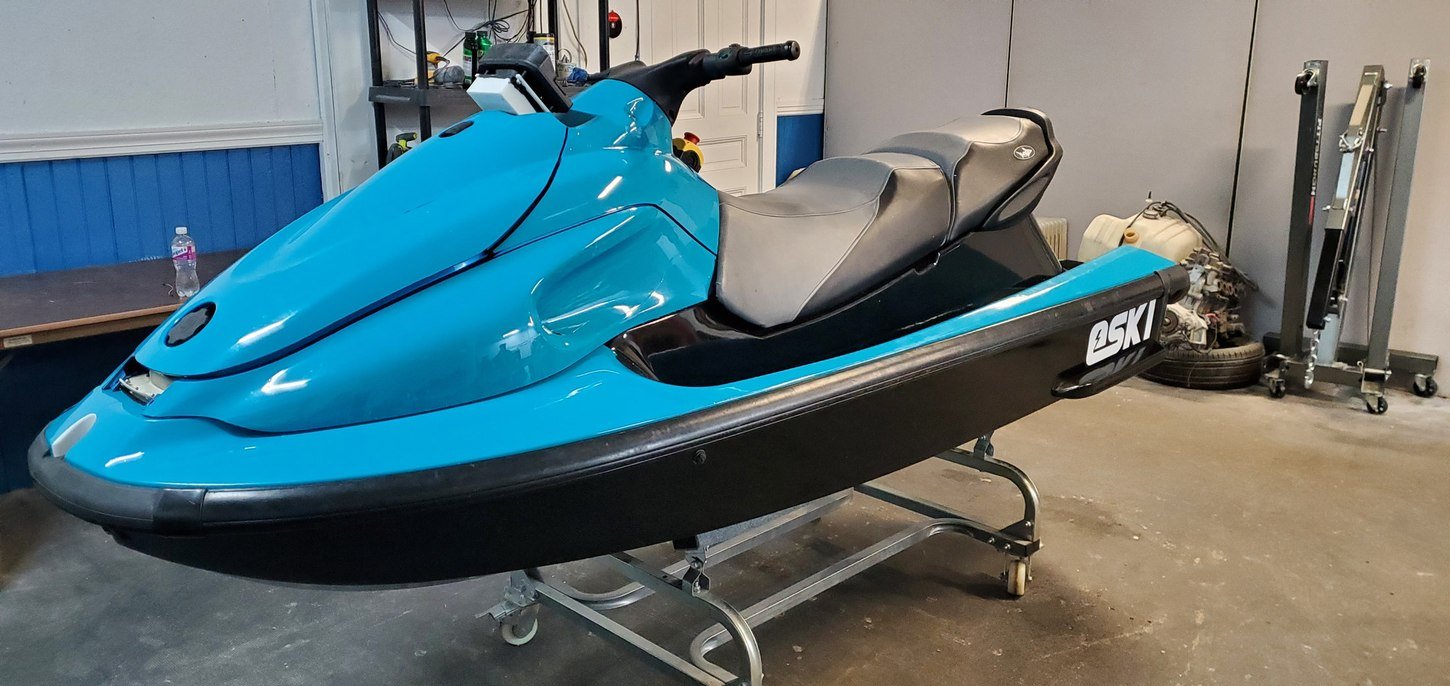
A 230 hp electric propulsion system is not just a motor and inverter. It's a vehicle-wide architecture where high-voltage power, thermal management, controls, safety, packaging, charging, and manufacturability have to agree.
As eSki's first engineering hire and technical lead, I worked across those interfaces through design, fabrication, integration, testing, and prototype demonstrations.
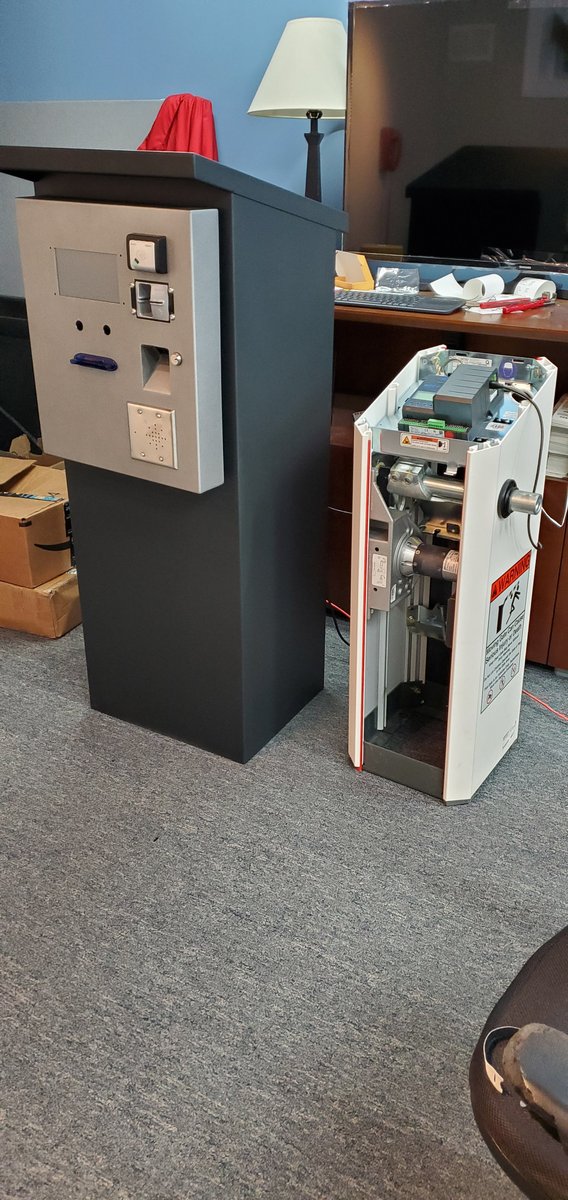
I pitched the automation concept and became its primary engineer, connecting ticketing, cash/payment hardware, barrier controls, C# software, and a SQL backend into a working prototype.
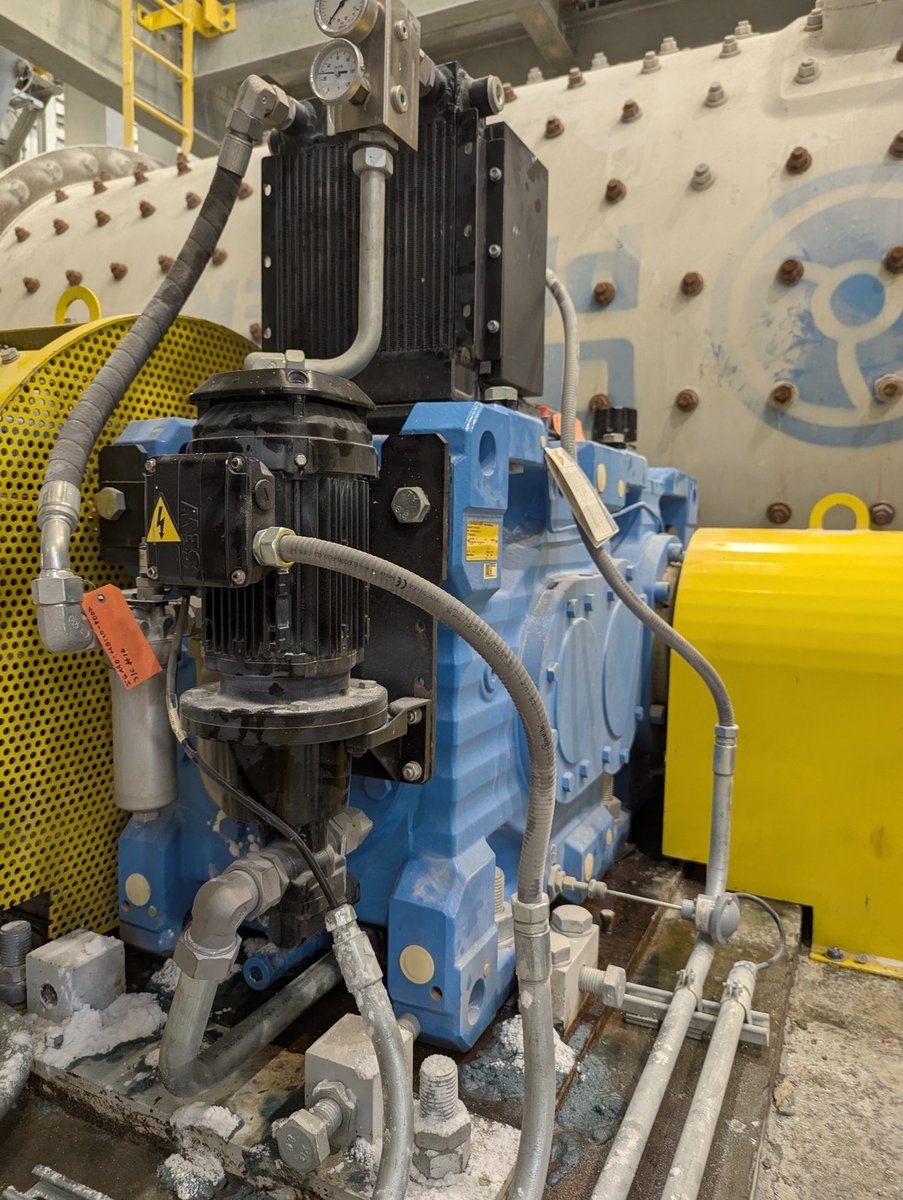
At a commercial-scale processing plant, I traced an intermittent shutdown to an internally shorted damper actuator, identified a dust-blocked pneumatic relief path behind sticking valves, and built a thermal model to assess likely undersized gearbox cooling.
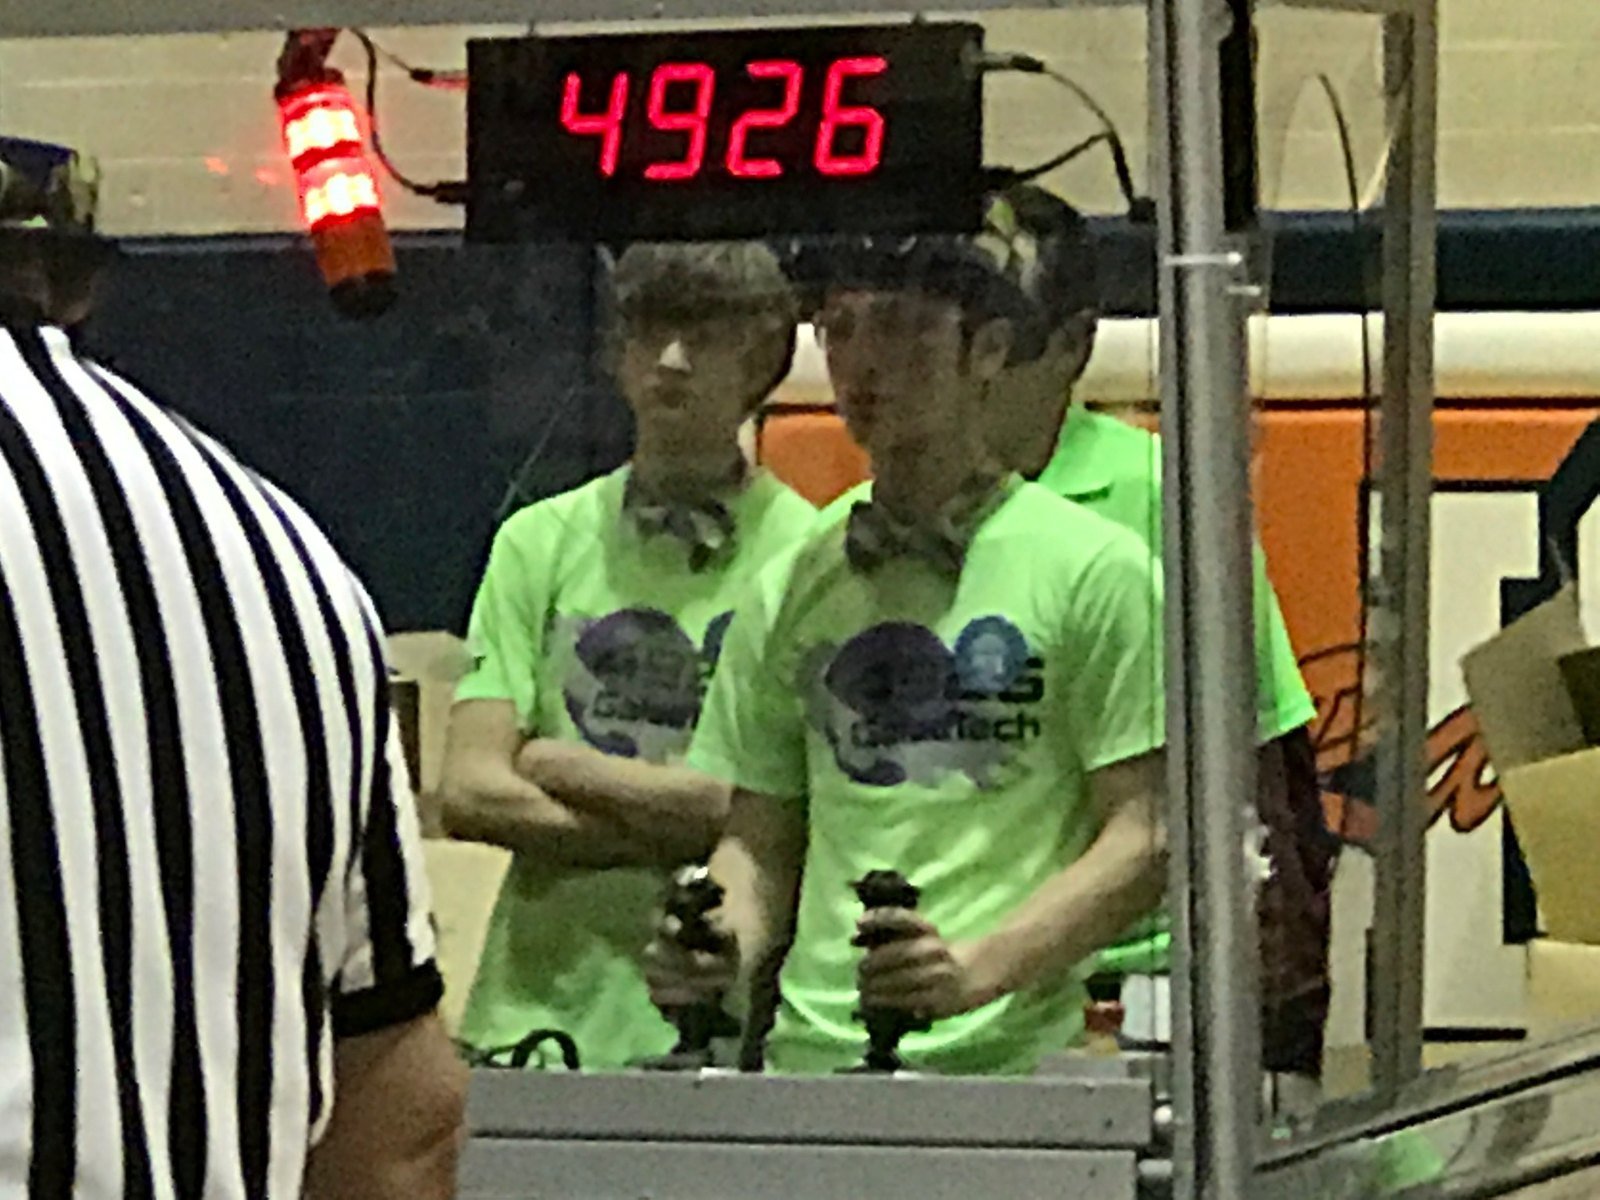
From FRC CAD, fabrication and four seasons as a robot driver to an autonomous electric go-kart developed during a summer engineering internship and a quadcopter whose code I wrote without third-party libraries, robotics shaped how I approach every complex system.
I'm most useful when a team needs more than another handoff. The work can begin at a blank page, a half-built prototype, or a machine that refuses to run consistently.
Have one of those problems?I turn requirements and half-formed ideas into architectures, trades, testable concepts, prototypes, and the first working pieces.
I look across power, controls, mechanics, software, interfaces, wiring, manufacturing, and real operating conditions to close the integration gap.
I instrument the problem, isolate failure modes, support commissioning, and translate lessons into design changes and clear operating knowledge.
CAD, wiring, code, test fixtures, fabrication, vendors, and field troubleshooting. I am comfortable moving between the design desk and the hardware.
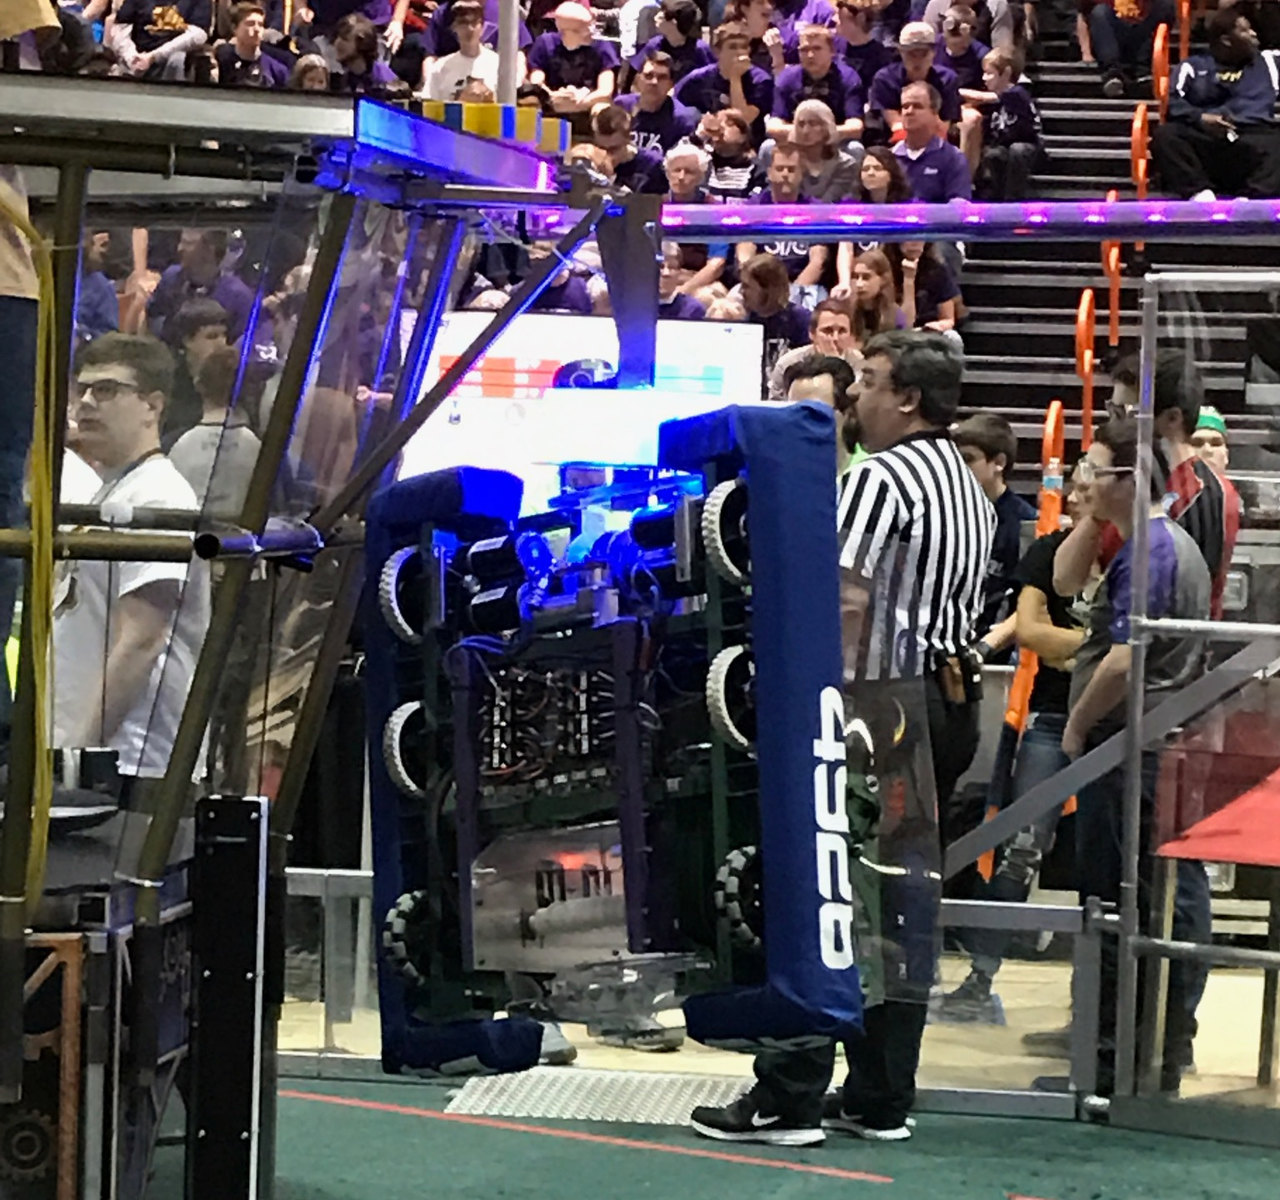 FIRST ROBOTICS: WHERE THE ENGINEERING MINDSET TOOK SHAPE.
I'm Reed Nowling. FIRST Robotics gave me the engineering mindset I still use today: learn what you don't know, take ownership, build with the resources available, and treat the prototype as the beginning of the real work.
That approach carried me through autonomy and embedded development, electrical and mechanical product integration, the first engineering role at a hardware startup, and industrial equipment that needed a systematic investigation more than another guess.
Most engineers can own a box on a system diagram. My best work is making the arrows between those boxes behave.
HyperMotionWorks is the independent engineering venture I am developing for the long term. Today the work is personal: one engineer with deep technical ownership, unusually broad execution skills, and close manufacturing relationships. I am selective about commitments and always interested in a worthwhile challenge.
An unusual role. An unfinished prototype. A stubborn machine. A project that needs someone willing to cross disciplines and take ownership of the integration. Start with the problem.
Selective collaborations and technical conversations. No obligation to arrive with a polished scope.